The handover task
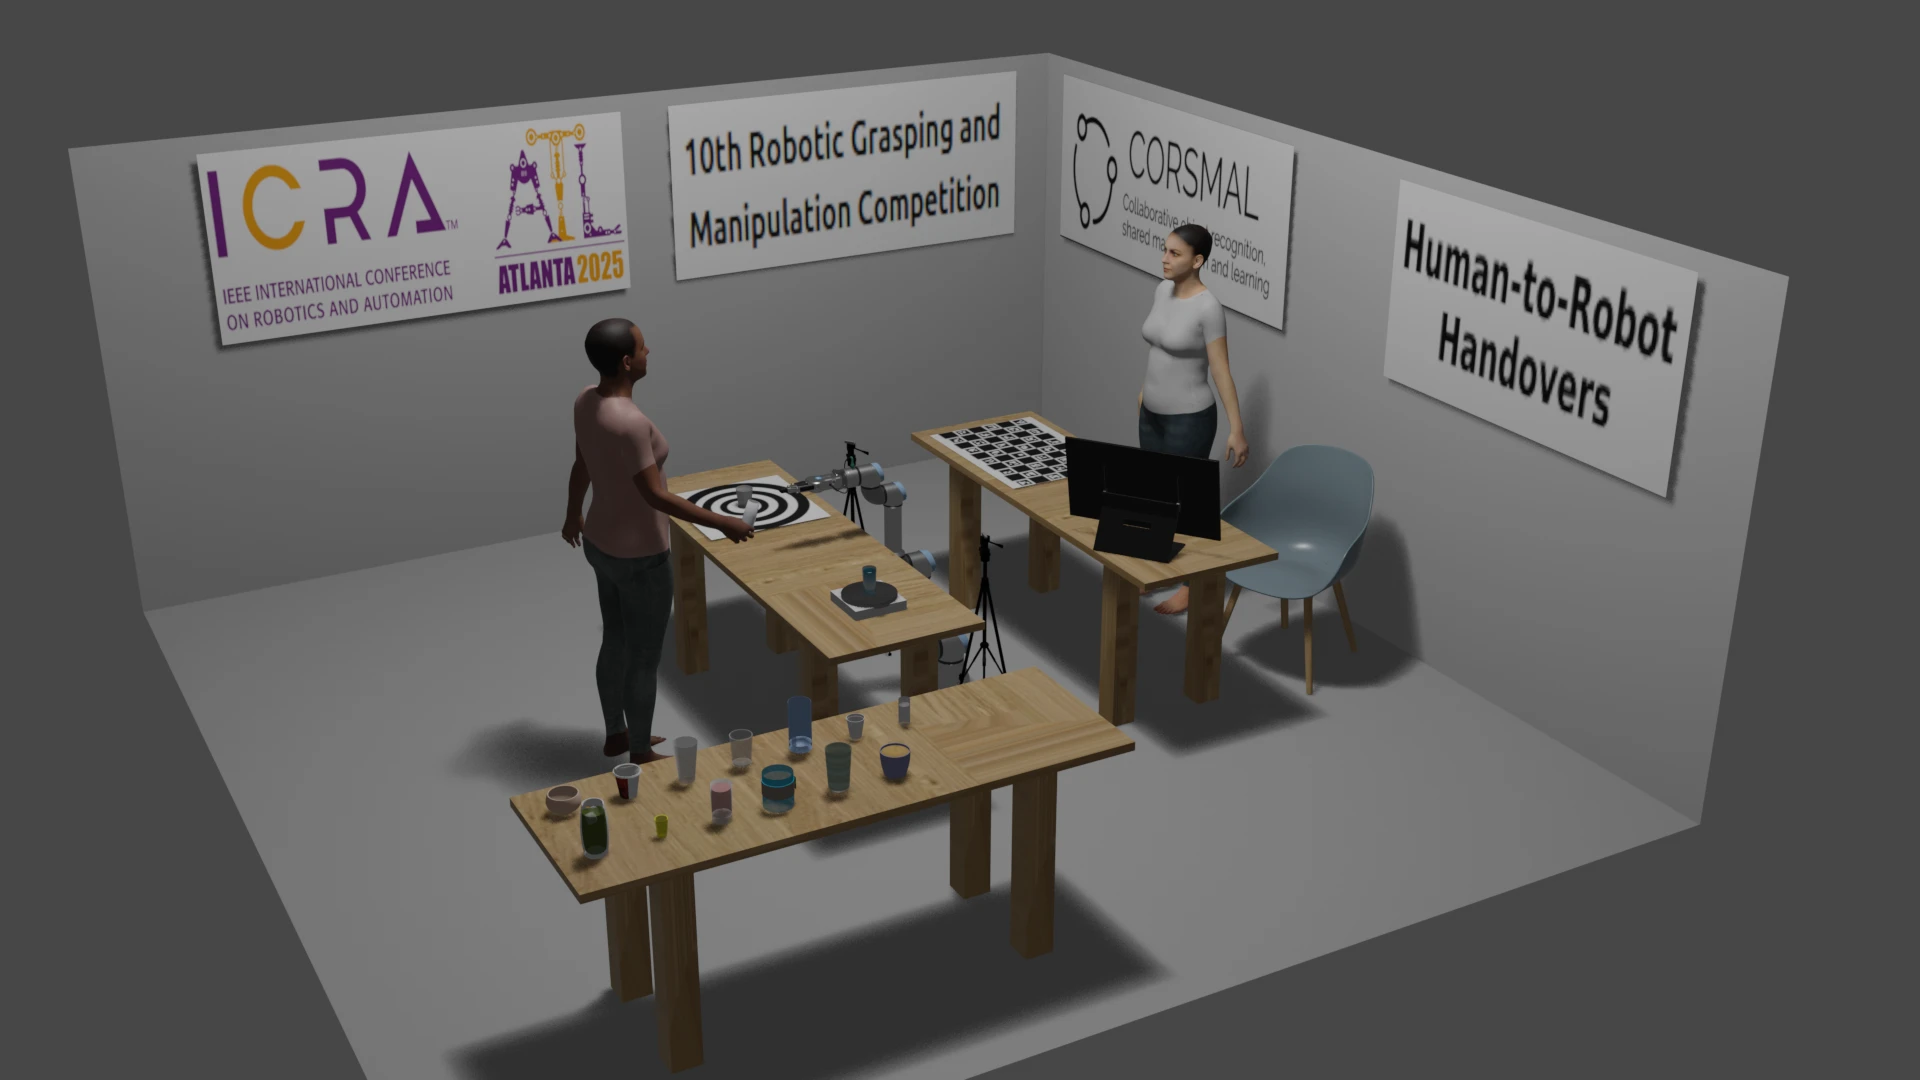
In this task, a person hands an object to a robot, which then delivers it to a designated area. The robot must adapt its actions to an object whose properties may be unknown.
The task comprises three stages:
- Human manoeuvring: The person grasps and moves the object towards the robot.
- Dynamic handover: The robot receives the object from the person.
- Robot manoeuvring: The robot moves the object to the designated delivery area.

Setup and safety
The setup supports a physical handover between a person and a robotic arm. Teams may explore perception and control approaches using one or more sensing modalities.
Safety is important when people and robots interact. Detailed setup and safety requirements for the 2027 track will be announced when confirmed.
Further information
Detailed task configurations and requirements will be announced as they are confirmed. Follow News & Media for updates.